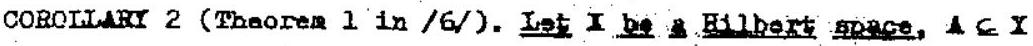Fixed points theorems for retractible mappings

Abstract

Authors

Mira-Cristiana Anisiu
Institutul de Matematica, Cluj-Napoca, Romania

Keywords

?

Paper coordinates

M.-C. Anisiu, Fixed points theorems for retractible mappings, Seminar on Functional Analysis and Numerical Methods, 1-10, Preprint, 89-1, Univ. Babeş-Bolyai Cluj-Napoca, 1989 (pdf file here)

PDF

About this paper

Journal

Preprint

Publisher Name

Babes-Bolyai University Cluj-Napoca, Romania

DOI
Print ISSN
Online ISSN

google scholar link

[1] M.C. Anisiu, Fixed points of retractible mappings with respect to the metric projection, ”Babes-Bolyai” Univ., Fac. of Math. Phys., Preprint nr.7, 1988, 87-96.
[2] M.C. Anisiu, V. Anisiu, On some conditions for the existence of the fixed points in Hilbert spaces, ”Babes-Bolyai” Univ., Fac. of Math. Phys., Preprint nr.6, 1989, 93-100.
[3] R.F. Brown, Retraction methods in Nielses fixed point theory, Pacific J. Math. 115 (1984), 277-298.
[4] W. Cheney, A.H. Goldstein, Proximity maps for convex sets, Proc. Amer. Math. Soc. 10 (1959), 448-450.
[5] G. Darbo, Punti uniti in transformazioni a condominio noncompatto, Rend. Sem. Mat. Univ. Padova 24 (1955), 84-92.
[6] T.C. Lin, C.L.Yen, Applications of the proximity map to fixed point theorems in Hilbert spaces, J. Approx. Theory 52 (1968), 141-148.
[7] I.A. Rus, The fixed point structures and the retraction mappings principle, ”Babes-Bolyai” Univ., Fac. of Math. Preprint nr.3, 1986, 175-184.
[8] S.P. Singh, B. Yatson, On approximating fixed points, Proc. of Symp. in Pure Math., Vol. 45 (1986), Part 2, 393-395.
[9] T.E. Willianson, The Leray-Schauder condition is necessary for existence of fixed points, Vol. 886, Lecture Notes in Math., Springer-Verlag, Berlin

1989-Anisiu-FixedPointTheorems html,body { width: 100%; height: 100%; } *, *::before,*::after { box-sizing: border-box; } body { margin: 0; color: #1E2029; font-size: 14px; line-height: normal; } hr { box-sizing: content-box; height: 0; overflow: visible; } h1, h2, h3, h4, h5, h6 { margin-top: 0; margin-bottom: 0.5em; color: rgba(0, 0, 0, 0.85); font-weight: 500; } p { margin-top: 0; margin-bottom: 1em; } ol, ul, dl { margin-top: 0; margin-bottom: 1em; } ol ol, ul ul, ol ul, ul ol { margin-bottom: 0; } dt { font-weight: 500; } dd { margin-bottom: 0.5em; margin-left: 0; } blockquote { margin: 0 0 1em; } dfn { font-style: italic; } b, strong { font-weight: bolder; } small { font-size: 80%; } sub, sup { position: relative; font-size: 75%; line-height: 0; vertical-align: baseline; } sub { bottom: -0.25em; } sup { top: -0.5em; } a { color: #0B93ff; text-decoration: none; background-color: transparent; outline: none; cursor: pointer; transition: color 0.3s; } a:hover { color: #33aaff; } a:active { color: #0070d9; } a:active, a:hover { text-decoration: none; outline: 0; } a[disabled] { color: rgba(0, 0, 0, 0.25); cursor: not-allowed; pointer-events: none; } pre, code, kbd, samp { font-size: 1em; } pre { margin-top: 0; margin-bottom: 1em; overflow: auto; } figure { margin: 0 0 1em; } img { vertical-align: middle; border-style: none; } svg:not(:root) { overflow: hidden; } table { border-collapse: collapse; } caption { padding-top: 0.75em; padding-bottom: 0.3em; color: rgba(0, 0, 0, 0.45); text-align: left; caption-side: bottom; } th { text-align: inherit; } mjx-container[jax="SVG"] { direction: ltr; } mjx-container[jax="SVG"] > svg { overflow: visible; min-height: 1px; min-width: 1px; } mjx-container[jax="SVG"] > svg a { fill: blue; stroke: blue; } mjx-assistive-mml { position: absolute !important; top: 0px; left: 0px; clip: rect(1px, 1px, 1px, 1px); padding: 1px 0px 0px 0px !important; border: 0px !important; display: block !important; width: auto !important; overflow: hidden !important; -webkit-touch-callout: none; -webkit-user-select: none; -khtml-user-select: none; -moz-user-select: none; -ms-user-select: none; user-select: none; } mjx-assistive-mml[display="block"] { width: 100% !important; } mjx-container[jax="SVG"][display="true"] { display: block; text-align: center; margin: 1em 0; } mjx-container[jax="SVG"][display="true"][width="full"] { display: flex; } mjx-container[jax="SVG"][justify="left"] { text-align: left; } mjx-container[jax="SVG"][justify="right"] { text-align: right; } g[data-mml-node="merror"] > g { fill: red; stroke: red; } g[data-mml-node="merror"] > rect[data-background] { fill: yellow; stroke: none; } g[data-mml-node="mtable"] > line[data-line], svg[data-table] > g > line[data-line] { stroke-width: 70px; fill: none; } g[data-mml-node="mtable"] > rect[data-frame], svg[data-table] > g > rect[data-frame] { stroke-width: 70px; fill: none; } g[data-mml-node="mtable"] > .mjx-dashed, svg[data-table] > g > .mjx-dashed { stroke-dasharray: 140; } g[data-mml-node="mtable"] > .mjx-dotted, svg[data-table] > g > .mjx-dotted { stroke-linecap: round; stroke-dasharray: 0,140; } g[data-mml-node="mtable"] > g > svg { overflow: visible; } [jax="SVG"] mjx-tool { display: inline-block; position: relative; width: 0; height: 0; } [jax="SVG"] mjx-tool > mjx-tip { position: absolute; top: 0; left: 0; } mjx-tool > mjx-tip { display: inline-block; padding: .2em; border: 1px solid #888; font-size: 70%; background-color: #F8F8F8; color: black; box-shadow: 2px 2px 5px #AAAAAA; } g[data-mml-node="maction"][data-toggle] { cursor: pointer; } mjx-status { display: block; position: fixed; left: 1em; bottom: 1em; min-width: 25%; padding: .2em .4em; border: 1px solid #888; font-size: 90%; background-color: #F8F8F8; color: black; } foreignObject[data-mjx-xml] { font-family: initial; line-height: normal; overflow: visible; } mjx-container[jax="SVG"] path[data-c], mjx-container[jax="SVG"] use[data-c] { stroke-width: 3; } #setText > div { justify-content: inherit; margin-top: 0; margin-bottom: 1em; } #setText div:last-child { margin-bottom: 0 !important; } #setText > br, #preview-content br { line-height: 1.2; } #preview-content > div { margin-top: 0; margin-bottom: 1em; } .proof > div, .theorem > div { margin-top: 1rem; } #preview-content table { margin-bottom: 1em; } #setText table { margin-bottom: 1em; } #preview-content .sub-table table, #setText .sub-table table { margin-bottom: 0; } mjx-container { text-indent: 0; overflow-y: hidden; overflow-x: auto; padding-top: 1px; padding-bottom: 1px; } .math-inline mjx-container { display: inline-block !important; page-break-inside: avoid; max-width: 100%; padding: 0; line-height: 0; } .math-inline[data-overflow="visible"] mjx-container { overflow: visible; } .math-inline mjx-container mjx-assistive-mml { max-width: 100%; } .math-block { align-items: center; page-break-after: auto; page-break-inside: avoid; margin: 0; display: block; /* mjx-container has block */ } .math-inline { display: inline-flex; /* mjx-container has inline-block. To prevent displacement during use overflow-x: auto;*/ max-width: 100%; } .math-block[data-width="full"] { overflow-x: auto; display: flex; /* mjx-container has flex */ } svg .math-inline { display: initial; max-width: initial; } svg .math-inline mjx-container { max-width: initial; } svg mjx-container { overflow: visible; padding: 0; } svg math-block[data-width="full"] { overflow: visible; } .math-block,.math-inline { --mmd-highlight-color: rgba(0, 147, 255, 0.25); --mmd-highlight-text-color: #1e2029; } .math-block[data-highlight-color] mjx-container[jax="SVG"] > svg { background-color: var(--mmd-highlight-color); } .math-block[data-highlight-text-color] mjx-container[jax="SVG"] > svg { color: var(--mmd-highlight-text-color); } .math-inline[data-highlight-color] mjx-container[jax="SVG"] { background-color: var(--mmd-highlight-color); } .math-inline[data-highlight-text-color] mjx-container[jax="SVG"] { color: var(--mmd-highlight-text-color); } .math-block p { flex-shrink: 1; } .math-block mjx-container { margin: 0 !important; } .math-error { background-color: yellow; color: red; } #preview-content img, #setText img { max-width: 100%; } #preview-content blockquote, #setText blockquote { page-break-inside: avoid; color: #666; margin: 0 0 1em 0; padding-left: 3em; border-left: .5em solid #eee; } #preview-content pre, #setText pre { border: none; padding: 0; overflow: auto; font-size: 85%; line-height: 1.45; border-radius: 6px; box-sizing: border-box; background: #f8f8fa; } #preview-content pre code, #setText pre code{ padding: 1rem; display: block; overflow-x: auto; line-height: 24px; } .empty { text-align: center; font-size: 18px; padding: 50px 0 !important; } #setText table, #preview-content table { display: table; overflow: auto; max-width: 100%; border-collapse: collapse; page-break-inside: avoid; } #setText table th, #preview-content table th { text-align: center; font-weight: bold; } #setText table td, #preview-content table td, #setText table th, #preview-content table th { border: 1px solid #dfe2e5; padding: 6px 13px; } #setText table tr, #preview-content table tr { background-color: #fff; border-top: 1px solid #c6cbd1; } #setText table tr:nth-child(2n), #preview-content table tr:nth-child(2n) { background-color: #f6f8fa; } #preview-content .main-title, #setText .main-title { text-align: center; line-height: 1.2; margin: 0 auto 1em auto; } #preview-content .author, #setText .author { text-align: center; margin: 0 auto; display: flex; justify-content: center; flex-wrap: wrap; } #preview-content .author p, #setText .author p { min-width: 30%; max-width: 50%; padding: 0 7px; } #preview-content .author > p > span, #setText .author > p > span { display: block; text-align: center; } #preview-content .section-title, #setText .section-title { margin-top: 1.5em; } #preview-content .abstract, #setText .abstract { text-align: justify; margin-bottom: 1em; } #preview-content .abstract p, #setText .abstract p { margin-bottom: 0; } @media print { #preview { font-size: 10pt!important; } svg { shape-rendering: crispEdges; } .math-block svg, math-inline svg { margin-top: 1px; } #preview-content img, #setText img { display: block; } #preview-content .figure_img img, #setText .figure_img img { display: inline; } .preview-right { word-break: break-word; } #preview-content h1, #setText h1 { page-break-inside: avoid; position: relative; border: 2px solid transparent; } #preview-content h1::after, #setText h1::after { content: ""; display: block; height: 100px; margin-bottom: -100px; position: relative; } #preview-content h2, #setText h2 { page-break-inside: avoid; position: relative; border: 2px solid transparent; } #preview-content h2::after, #setText h2::after { content: ""; display: block; height: 100px; margin-bottom: -100px; position: relative; } #preview-content h3, #setText h3 { page-break-inside: avoid; position: relative; border: 2px solid transparent; } #preview-content h3::after, #setText h3::after { content: ""; display: block; height: 100px; margin-bottom: -100px; position: relative; } #preview-content h4, #setText h4 { page-break-inside: avoid; position: relative; border: 2px solid transparent; } #preview-content h4::after, #setText h4::after { content: ""; display: block; height: 100px; margin-bottom: -100px; position: relative; } #preview-content h5, #setText h5 { page-break-inside: avoid; position: relative; border: 2px solid transparent; } #preview-content h5::after, #setText h5::after { content: ""; display: block; height: 100px; margin-bottom: -100px; position: relative; } #preview-content h6, #setText h6 { page-break-inside: avoid; position: relative; border: 2px solid transparent; } #preview-content h6::after, #setText h6::after { content: ""; display: block; height: 100px; margin-bottom: -100px; position: relative; } } #preview-content sup, #setText sup { top: -.5em; position: relative; font-size: 75%; line-height: 0; vertical-align: baseline; } #preview-content .text-url, #setText .text-url { color: #0B93ff; cursor: text; pointer-events: none; } #preview-content .text-url a:hover, #setText .text-url a:hover { color: #0B93ff; } mark { background-color: #feffe6; } span[data-underline-type] mark { background: inherit; background-color: #feffe6; padding-top: 0; padding-bottom: 0; } *[data-has-dotfill] { position: relative; overflow: hidden; } *[data-has-dotfill] .dotfill::after { position: absolute; padding-left: .25ch; content: " . . . . . . . . . . . . . . . . . . . " ". . . . . . . . . . . . . . . . . . . . . . . " ". . . . . . . . . . . . . . . . . . . . . . . " ". . . . . . . . . . . . . . . . . . . . . . . " ". . . . . . . . . . . . . . . . . . . . . . . " ". . . . . . . . . . . . . . . . . . . . . . . " ". . . . . . . . . . . . . . . . . . . . . . . "; text-align: right; } .smiles { text-align: center; } div.svg-container, #setText > div.svg-container { display: flex; justify-content: center; } #preview-content code, #setText code { font-family: Inconsolata; font-size: inherit; display: initial; background: #f8f8fa; } #preview-content .mmd-highlight code, #setText .mmd-highlight code, #preview-content pre.mmd-highlight code, #setText pre.mmd-highlight code { background-color: transparent; } #preview-content pre code, #setText pre code { font-family: 'DM Mono', Inconsolata, monospace; color: #333; font-size: 15px; } .hljs-comment, .hljs-quote { color: #998; font-style: italic; } .hljs-command { color: #005cc5; } .hljs-keyword, .hljs-selector-tag, .hljs-subst { color: #d73a49; font-weight: bold; } .hljs-number, .hljs-literal, .hljs-variable, .hljs-template-variable, .hljs-tag .hljs-attr { color: #005cc5; } .hljs-string, .hljs-doctag { color: #24292e; } .hljs-title, .hljs-section, .hljs-selector-id { color: #6f42c1; font-weight: bold; } .hljs-subst { font-weight: normal; } .hljs-type, .hljs-class .hljs-title { color: #458; font-weight: bold; } .hljs-tag, .hljs-name, .hljs-attribute { color: #000080; font-weight: normal; } .hljs-regexp, .hljs-link { color: #009926; } .hljs-symbol, .hljs-bullet { color: #990073; } .hljs-built_in, .hljs-builtin-name { color: #24292e; } .hljs-meta { color: #999; font-weight: bold; } .hljs-meta-keyword { color: #d73a49; } .hljs-meta-string { color: #032f62; } .hljs-deletion { background: #fdd; } .hljs-addition { background: #dfd; } .hljs-emphasis { font-style: italic; } .hljs-strong { font-weight: bold; } .table_tabular table th, .table_tabular table th { border: none !important; padding: 6px 13px; } .tabular tr, .tabular tr { border-top: none !important; border-bottom: none !important; } .tabular td, .tabular td { border-style: none !important; background-color: #fff; border-color: #000 !important; word-break: keep-all; padding: 0.1em 0.5em !important; } .tabular { display: inline-table !important; height: fit-content; } .tabular td > p { margin-bottom: 0; margin-top: 0; } .tabular td._empty { height: 1.3em; } .tabular td .f { opacity: 0; } html[data-theme="dark"] .tabular tr, html[data-theme="dark"] .tabular td { background-color: #202226; border-color: #fff !important; } .table_tabular { overflow-x: auto; padding: 0 2px 0.5em 2px; } .figure_img { margin-bottom: 0.5em; overflow-x: auto; } ol.enumerate, ul.itemize { padding-inline-start: 40px; } /* It's commented because counter not supporting to change value ol.enumerate.lower-alpha { counter-reset: item ; list-style-type: none !important; } .enumerate.lower-alpha > li { position: relative; } .enumerate.lower-alpha > li:before { content: "("counter(item, lower-alpha)")"; counter-increment: item; position: absolute; left: -47px; width: 47px; display: flex; justify-content: flex-end; padding-right: 7px; flex-wrap: nowrap; word-break: keep-all; } */ .itemize > li { position: relative; } .itemize > li > span.li_level, .li_enumerate.not_number > span.li_level { position: absolute; right: 100%; white-space: nowrap; width: max-content;; display: flex; justify-content: flex-end; padding-right: 10px; box-sizing: border-box; } .li_enumerate.not_number { position: relative; display: inline-block; list-style-type: none; } #preview { font-family: 'CMU Serif', 'Georgia', Helvetica, Arial, sans-serif; font-size: 17px; visibility: visible; word-break: break-word; padding: 2.5em; max-width: 800px; margin: auto; box-sizing: content-box; } #preview h1, #preview h2, #preview h3, #preview h4, #preview h5, #preview strong { font-family: 'CMU Serif Bold', 'Georgia', Helvetica, Arial, sans-serif; } #preview i, #preview em { font-family: 'CMU Serif Italic', 'Georgia', Helvetica, Arial, sans-serif; } .mmd-menu { max-width: 320px; position: absolute; background-color: white; color: black; width: auto; padding: 5px 0px; border: 1px solid #E5E6EB; margin: 0; cursor: default; font: menu; text-align: left; text-indent: 0; text-transform: none; line-height: normal; letter-spacing: normal; word-spacing: normal; word-wrap: normal; white-space: nowrap; float: none; z-index: 201; border-radius: 5px; -webkit-border-radius: 5px; -moz-border-radius: 5px; -khtml-border-radius: 5px; box-shadow: 0px 10px 20px #808080; -webkit-box-shadow: 0px 10px 20px #808080; -moz-box-shadow: 0px 10px 20px #808080; -khtml-box-shadow: 0px 10px 20px #808080; } .mmd-menu:focus { outline: none; } .mmd-menu.mmd-menu-sm { max-width: 100vw; padding-bottom: 34px; border-radius: 0; -webkit-border-radius: 0; -moz-border-radius: 0; -khtml-border-radius: 0; } .mmd-menu-item-icon { color: #1e2029; margin-left: auto; align-items: center; display: flex; flex-shrink: 0; display: none; } .mmd-menu-item { padding-bottom: 8px; padding-top: 8px; padding-left: 1.25rem; padding-right: 1.25rem; display: flex; background: transparent; height: 52px; max-height: 52px; } .mmd-menu-item:focus { outline: none; } .mmd-menu-item.active { background-color: #e1e0e5; } .mmd-menu-item.active .mmd-menu-item-icon { display: flex; } .mmd-menu-item-container { overflow: hidden; } .mmd-menu-item-title { color: #1e2029; white-space: nowrap; text-overflow: ellipsis; overflow: hidden; font-size: 14px; line-height: 20px; } .mmd-menu-item-value { color: #7d829c; white-space: nowrap; text-overflow: ellipsis; overflow: hidden; font-size: 12px; line-height: 16px; } html[data-theme="dark"] .mmd-menu-item-title { color: #ebefe7; } html[data-theme="dark"] .mmd-menu-item.active .mmd-menu-item-title { color: #1e2029; } html[data-theme="dark"] .mmd-menu { background-color: #33363a; } .mmd-context-menu-overlay{ background: rgba(0, 0, 0, 0.56); } .ClipboardButton { padding: 0; margin: 0.5rem; display: inline-block; cursor: pointer; color: rgb(36, 41, 47); background: rgb(246, 248, 250); border-radius: 6px; border: 1px solid rgba(31, 35, 40, 0.15); box-shadow: rgba(31, 35, 40, 0.04) 0 1px 0 0, rgba(255, 255, 255, 0.25) 0 1px 0 0 inset; position: relative; } .ClipboardButton:hover { background-color: rgb(243, 244, 246); border-color: rgba(31, 35, 40, 0.15); transition-duration: .1s; } .mmd-clipboard-icon { fill: currentColor; vertical-align: text-bottom; } .mmd-clipboard-copy-icon { color: rgb(101, 109, 118); } .mmd-clipboard-check-icon { color: rgb(26, 127, 55); } .mmd-tooltipped-no-delay:hover::before, .mmd-tooltipped-no-delay:hover::after { animation-delay: 0s; } .mmd-tooltipped:hover::before, .mmd-tooltipped:hover::after { display: inline-block; text-decoration: none; animation-name: tooltip-appear; animation-duration: .1s; animation-fill-mode: forwards; animation-timing-function: ease-in; animation-delay: .4s; } .mmd-tooltipped-w::before { top: 50%; bottom: 50%; left: -7px; margin-top: -6px; border-left-color: rgb(36, 41, 47); } .mmd-tooltipped::before { position: absolute; z-index: 1000001; display: none; width: 0; height: 0; color: rgb(36, 41, 47); pointer-events: none; content: ""; border: 6px solid transparent; opacity: 0; } .mmd-tooltipped-w::after { right: 100%; bottom: 50%; margin-right: 6px; transform: translateY(50%); } .mmd-tooltipped::after { position: absolute; z-index: 1000000; display: none; padding: 0.5em 0.75em; font: normal normal 11px/1.5 'CMU Serif', 'Georgia', Helvetica, Arial, sans-serif; -webkit-font-smoothing: subpixel-antialiased; color: rgb(255, 255, 255); text-align: center; text-decoration: none; text-shadow: none; text-transform: none; letter-spacing: normal; word-wrap: break-word; white-space: pre; pointer-events: none; content: attr(aria-label); background: rgb(36, 41, 47); border-radius: 6px; opacity: 0; }
"BASES-BOLYAT" UNTVERSITT
Faculty of Cathematics and Digisies
Resuarch Seminars
Seminar on Punctional Analysis and Numerical Uetiods
Preprint Nr. 1, 1989, pp. 1 - 10.
FIXED POTNT THEORENS FOR
BÉTHACTITHETE MAPPINGS
Mira-Cristlana Anisiu
The fixed point theorems in this paper axtand some results in / 6 / / 6 / //6/// 6 //6/; if the retract is chosen to be the metric projection one abtains same known theorems.
We state firstly some dofinitions to be used in the following.
Iret X X XXX be a nonvoid set and l ∉ A ≤ X l ∉ A ≤ X l!in A <= Xl \notin A \leq Xl∉A≤X. A A AAA map r t X → Λ r t X → Λ rtX rarr Lambdar t X \rightarrow \LambdartX→Λ is a reEract of X X XXX on A A AAA if the restriction of r r rrr to the sot A A AAA is tha identity map id A : A → A . A A : A → A . A _(A):A rarr A.A{ }_{A}: A \rightarrow A . AA:A→A.A map f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X is retractible on A A AAA with respect to the retract x x xxx if Fix rof = F i x f = F i x f =Fixf=F i x f=Fixf, where "Fix" donotes the sot of the fixed points of 2 map /3,?,1/.
It is obvious that always Fix rof ⊆ ⊆ sube\subseteq⊆ Fix f f fff, so in the definition. of the rotractible map one can darand only Fix f ⊆ F i x f ⊆ F i x f sube Fixf \subseteq F i xf⊆Fix rof. Brown in /3/ has given the following necossary and sufficient condition for the map f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X to ba ratractible on A A AAA with raspect te, the retract r :
x ˙ ∈ r ( f ( A ) ∖ A ) x ˙ ∈ r ( f ( A ) ∖ A ) x^(˙)in r(f(A)\\A)\dot{x} \in r(f(A) \backslash A)x˙∈r(f(A)∖A) impliss f ( x ) = x f ( x ) = x f(x)=xf(x)=xf(x)=x or f ( x ) ∉ r − 1 ( x ) f ( x ) ∉ r − 1 ( x ) f(x)!inr^(-1)(x)f(x) \notin r^{-1}(x)f(x)∉r−1(x).
Lat B B BBB be a bounded nonampty sat in tha patric spaca X X XXX. The gassure of noncompactness in tha zanse of Kuratowsty, denated a ( B ) a ( B ) a(B)a(B)a(B), is the infimum of the numbers α α alpha\alphaα such that the set B B BBB can be covered
by 4 finite namber of subsets of X X XXX of diameter leas than or equal to α α alpha\alphaα.
Let A A AAA be a monvoid subset of the metric space X ¯ X ¯ bar(X)\bar{X}X¯ and I : A → X I : A → X I:A rarr XI: A \rightarrow XI:A→X a aap. If there exists k , c ⩽ k ⩽ 1 k , c ⩽ k ⩽ 1 k,c <= k <= 1k, c \leqslant k \leqslant 1k,c⩽k⩽1 such that for each nonempty subset B B BBB of A, B baing bounded, wo have
a ( f ( B ) ) ⩽ k a ( B ) a ( f ( B ) ) ⩽ k a ( B ) a(f(B)) <= ka(B)a(f(B)) \leqslant k a(B)a(f(B))⩽ka(B),
then f f fff is called x x xxx-set-contractive.
Bach nonexpansive map f : Λ → X ( f : Λ → X ( f:Lambda rarr X(f: \Lambda \rightarrow X(f:Λ→X( i.e. d ( f ( x ) , f ( y ) ) ⩽ d ( x , y ) d ( f ( x ) , f ( y ) ) ⩽ d ( x , y ) d(f(x),f(y)) <= d(x,y)d(f(x), f(y)) \leqslant d(x, y)d(f(x),f(y))⩽d(x,y) for each x , y x , y x,yx, yx,y in A) is obviously l-eiet-contractive.
In. the following we give a generalization of Theorem I in /6/, using in the proof the fixed point theoren of Darbot
THEORS: 1 /5/. Let X X XXX be a Banach space, A ⊆ X A ⊆ X A sube XA \subseteq XA⊆X a closed convex nonvoid set, f : A ⟶ A f : A ⟶ A f:A longrightarrow Af: A \longrightarrow Af:A⟶A continuous k k kkk-set-contractive with 0 < k < j 0 < k < j 0 < k < j0<k<j0<k<j. such that Z ( A ) Z ( A ) Z(A)\mathbb{Z}(\mathbb{A})Z(A) is a bounded set. Then Fix f ≠ ∅ f ≠ ∅ f!=O/f \neq \varnothingf≠∅.
In the initial form of Darbo'a theorem A is bounded, but it ∵ ∵ :'\because∵ suffices to roquiro f ( A ) f ( A ) f(A)f(A)f(A) bounded, taking A 1 = c l c o f ( A ) ⊆ A A 1 = c l c o f ( A ) ⊆ A A_(1)=clcof(A)sube AA_{1}=c l c o f(A) \subseteq AA1=clcof(A)⊆A and f : A 1 → A 1 f : A 1 → A 1 f:A_(1)rarrA_(1)f: A_{1} \rightarrow A_{1}f:A1→A1.
Me nead also the following
Insuld 1. Let X X XXX be a normed space, C ⊆ X C ⊆ X C sube XC \subseteq XC⊆X and f : C ⟶ X f : C ⟶ X f:C longrightarrow Xf: C \longrightarrow Xf:C⟶X, such that ( I − f ) ( C ) ( I − f ) ( C ) (I-f)(C)(I-f)(C)(I−f)(C) is a closed sot. If there oxiats a sequonce of ㄱapsf n , C → X , n ⩾ 1 n , C → X , n ⩾ 1 n,C rarr X,n >= 1n, C \rightarrow X, n \geqslant 1n,C→X,n⩾1, each of them having e fixed point x n ( f n ( x n ) = x n ) , f n x n f n x n = x n , f n x_(n)(f_(n)(x_(n))=x_(n)),f_(n)x_{n} \left(f_{n}\left(x_{n}\right)=x_{n}\right), f_{n}xn(fn(xn)=xn),fn converging uniformly to f 1 f 1 f_(1)f_{1}f1 then f has also a fixed f has also a fixed  f_("has also a fixed ")f_{\text {has also a fixed }}fhas also a fixed  point.
Proof. Denote s , g n : C → I , g = I − f , g n = I − f n , n ≥ 1 s , g n : C → I , g = I − f , g n = I − f n , n ≥ 1 s,g_(n):C rarrI,g=I-f,g_(n)=I-f_(n),n >= 1\mathrm{s}, \mathrm{g}_{\mathrm{n}}: C \rightarrow \mathrm{I}, \mathrm{g}=I-f, \mathrm{~g}_{\mathrm{n}}=I-f_{\mathrm{n}}, n \geq 1s,gn:C→I,g=I−f, gn=I−fn,n≥1. Fach I n I n I_(n)I_{n}In having a fixed point, it follows that each g n g n g_(n)g_{n}gn has a zero, heace o ∈ g n ( d ) o ∈ g n ( d ) o ing_(n)(d)o \in g_{n}(d)o∈gn(d). Because f n → n f f n → n f f_(n)rarr"n"ff_{n} \xrightarrow{n} ffn→nf uniforaly; g n → n g g n → n g g_(n)rarr"n"gg_{n} \xrightarrow{n} ggn→ng uniformly.
Int ε > 0 ε > 0 epsi > 0\varepsilon>0ε>0 be arbitrarily chosen; Irom the uniform convergenció of g n g n g_(n)g_{n}gn to g g ggg one obtains g 6 ⩾ 1 g 6 ⩾ 1 g_(6) >= 1g_{6} \geqslant 1g6⩾1 such that
‖ g x ( x ) − g ( x ) ‖ < ε g x ( x ) − g ( x ) < ε ||g_(x)(x)-g(x)|| < epsi\left\|g_{x}(x)-g(x)\right\|<\varepsilon‖gx(x)−g(x)‖<ε for each n ⩾ n ε n ⩾ n ε n >= n_(epsi)n \geqslant n_{\varepsilon}n⩾nε and x x xxx in C C CCC.
It follows that for each n ⩾ n E n ⩾ n E n >= n_(E)n \geqslant n_{E}n⩾nE we have
E n ( C ) ⊆ E ( C ) + B ( 0 , E ) E n ( C ) ⊆ E ( C ) + B ( 0 , E ) E_(n)(C)sube E(C)+B(0,E)E_{n}(C) \subseteq E(C)+B(0, E)En(C)⊆E(C)+B(0,E).
Therafore 0 ∈ E ( C ) + B ( 0 , ε ) 0 ∈ E ( C ) + B ( 0 , ε ) 0in E(C)+B(0,epsi)0 \in E(C)+B(0, \varepsilon)0∈E(C)+B(0,ε) for each ε > 0 ε > 0 epsi > 0\varepsilon>0ε>0 and 0 ∈ 0 ∈ 0in0 \in0∈ cl g ( C ) g ( C ) g(C)g(C)g(C). = g ( C ) = g ( C ) =g(C)=g(C)=g(C). This means'that there exists x ∈ C x ∈ C x in Cx \in Cx∈C such that f ( x ) = x ˙ f ( x ) = x ˙ f(x)=x^(˙)f(x)=\dot{x}f(x)=x˙.
Now we can prove the following
THEOREM 2. Let X X XXX be a Banach spēce, A ⊆ X A ⊆ X A sube XA \subseteq XA⊆X a nonvoid closéd convex set; f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X and r : X → A r : X → A r:X rarr Ar: X \rightarrow Ar:X→A such that F = F = F=F=F= rof : A → A : A → A :A rarr A: A \rightarrow A:A→A is a continuous 1-set-contractive map having P ( A ) P ( A ) P(A)P(A)P(A) bounded and ( I − f ) ( A ) ( I − f ) ( A ) (I-f)(A)(I-f)(A)(I−f)(A) a closed set. Then Fix rof ∉ ∅ ∉ ∅ !in O/\notin \varnothing∉∅.
Proof. Let t ∈ ( 0 , 1 ) , x 0 ∈ A t ∈ ( 0 , 1 ) , x 0 ∈ A t in(0,1),x_(0)in At \in(0,1), x_{0} \in At∈(0,1),x0∈A and F t = t F + ( 1 − t ) x 0 F t = t F + ( 1 − t ) x 0 F_(t)=tF+(1-t)x_(0)F_{t}=t F+(1-t) x_{0}Ft=tF+(1−t)x0. We show that F t F t F_(t)F_{t}Ft is t t ttt-set contractive.
Let B ⊆ A B ⊆ A B sube AB \subseteq AB⊆A a bounded subset ; then
a ( F t ( B ) ) = a ( t P ( B ) + ( I − t ) x 0 ) ⩽ a ( t P ( B ) ) = t a ( P ( B ) ) ⩽ t a ( B ) a F t ( B ) = a t P ( B ) + ( I − t ) x 0 ⩽ a ( t P ( B ) ) = t a ( P ( B ) ) ⩽ t a ( B ) a(F_(t)(B))=a(tP(B)+(I-t)x_(0)) <= a(tP(B))=ta(P(B)) <= ta(B)a\left(F_{t}(B)\right)=a\left(t P(B)+(I-t) x_{0}\right) \leqslant a(t P(B))=t a(P(B)) \leqslant t a(B)a(Ft(B))=a(tP(B)+(I−t)x0)⩽a(tP(B))=ta(P(B))⩽ta(B).
Applying Darbo's theorem, each F t F t F_(t)F_{t}Ft has a fixed point x t x t x_(t)x_{t}xt. Considering t n → 1 , t n < 1 t n → 1 , t n < 1 t_(n)rarr1,t_(n) < 1t_{n} \rightarrow 1, t_{n}<1tn→1,tn<1 we obtain for each x x xxx in A A AAA
‖ F t n ( x ) − F ( x ) ‖ = ( 1 − t n ) ‖ F ( x ) − x 0 ‖ ⩽ F t n ( x ) − F ( x ) = 1 − t n F ( x ) − x 0 ⩽ ||F_(t_(n))(x)-F(x)||=(1-t_(n))||F(x)-x_(0)|| <=\left\|F_{t_{n}}(x)-F(x)\right\|=\left(1-t_{n}\right)\left\|F(x)-x_{0}\right\| \leqslant‖Ftn(x)−F(x)‖=(1−tn)‖F(x)−x0‖⩽
⩽ ( 1 − t n ) d ( x 0 ′ , F ( A ) ) → t n → 1 0 , ⩽ 1 − t n d x 0 ′ , F ( A ) → t n → 1 0 , <= (1-t_(n))d(x_(0)^('),F(A))rarr"t_(n)rarr1"0,\leqslant\left(1-t_{n}\right) d\left(x_{0}^{\prime}, F(A)\right) \xrightarrow{t_{n} \rightarrow 1} 0,⩽(1−tn)d(x0′,F(A))→tn→10,.
bence F t n ⟶ F F t n ⟶ F F_(t_(n))longrightarrow F\mathrm{F}_{\mathrm{t}_{\mathrm{n}}} \longrightarrow FFtn⟶F uniformly on A .
Now Lema 1 applies and Fix F ∉ ∅ F ∉ ∅ F!in O/F \notin \varnothingF∉∅.
In the above theorem, instead of ( I − F ) ( Λ ) ( I − F ) ( Λ ) (I-F)(Lambda)(I-F)(\Lambda)(I−F)(Λ) to be closod, one could require ( I − F I − F I-FI-FI−F ) (cl co F ( A ) F ( A ) F(A)F(A)F(A) ) to be closed to X X XXX, considering the restriction of F F FFF on el co F ( A ) F ( A ) F(A)F(A)F(A), whose range is also in cl co r → ( A ) r → ( A ) vec(r)(A)\vec{r}(A)r→(A).
In the terms of F F FFF, Theorem 2 is exactely Lemma 1 in / 6 / / 6 / //6/// 6 //6/, given there without proof.
4 natural example of a map x : X → A x : X → A x:X rarr Ax: X \rightarrow Ax:X→A is the meteric projection, which is well-defined if for mample x x xxx is aniformly convex.In thls case we obtain obviously
COROLTARY 1.Let X X XXX be a prifornaly convex Bagach Boach i ⊆ X i ⊆ X i sube Xi \subseteq Xi⊆X ㅡ nonvoid closed convex fat, f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X ang P = F , t x → A P = F , t x → A P=F,tx rarr AP=F, t x \rightarrow AP=F,tx→A the metric projection.If P = p ∘ f : A → A P = p ∘ f : A → A P=p@f:A rarr AP=p \circ f: A \rightarrow AP=p∘f:A→A as a continuigs 1-getcog- tructive men with F ( Λ ) F ( Λ ) F(Lambda)F(\Lambda)F(Λ) bounded and(I.F )( A A AAA )cloged get,then Rix pof ≠ 0 ≠ 0 !=0\neq 0≠0 .
The conclusion means axactely that there oxists x x xxx in a ach that par ( x ) = x , 1 4 , 0.1 − f ( x ) = d ( f ( x ) , 1 ) ( x ) = x , 1 4 , 0.1 − f ( x ) = d ( f ( x ) , 1 ) (x)=x,(1)/(4),0.1-f(x)=d(f(x),1)(x)=x, \frac{1}{4}, 0.1-f(x)=d(f(x), 1)(x)=x,14,0.1−f(x)=d(f(x),1) this raspht appears in the well-icnomn theorem of X ¯ y X ¯ y bar(X)y\bar{X} yX¯y Fan(1969)gtyan for a namveld com- pact convex subset K K KKK of a normed space X X XXX and continuous map I I III : : K ⟶ K : K ⟶ K :KlongrightarrowK: \mathrm{K} \longrightarrow \mathrm{K}:K⟶K.
a nonvoid slosed convex set, f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X ig continuous 1 − 1 − 1-1-1− setchontrac- tive map.We suppose that althgr ( I − p o f ) ( A ) ( I − p o f ) ( A ) (I-pof)(A)(I-p o f)(A)(I−pof)(A) is closed gr( I − I − I-I-I− -pof)(cl co pef(A))is closed in x x xxx, whers p = P A : x → A p = P A : x → A p=P_(A):x rarr Ap=P_{A}: x \rightarrow Ap=PA:x→A is the metric profection.If f ( A ) f ( A ) f(A)f(A)f(A) is bounded,then there exists u in such that
‖ u − f ( u ) ‖ = d ( f ( u ) , Λ ) ‖ u − f ( u ) ‖ = d ( f ( u ) , Λ ) ||u-f(u)||=d(f(u),Lambda)\|u-f(u)\|=d(f(u), \Lambda)‖u−f(u)‖=d(f(u),Λ).
Proof.Because f , t → X ˙ f , t → X ˙ f,t rarrX^(˙)f, t \rightarrow \dot{X}f,t→X˙ is continneus 1-set-contractive and i p : X → A p : X → A p:X rarr Ap: X \rightarrow Ap:X→A is nonexpansive / 4 / / 4 / //4/// 4 //4/ ,it follows that F = p a r F = p a r F=parF=p a rF=par is a conti- nuous 1-sht-contractive map.The fact that f ( A ) f ( A ) f(A)f(A)f(A) is bourded implios F ( A ) F ( A ) F(A)F(A)F(A) boundad and Cerellary 1 applies.
It is obvieus that in Caroliary 2 ,ingtend of 1 ( 1 ) 1 ( 1 ) 1(1)1(1)1(1) to be bounded it is enough the require pof(A)to be boandad.
In the papar/4/there mew given many results which fallow from Corsllary 2,mong mich theorems of Isn,Singh and Hatison.
If in Theorein 1 we can choose r : X → Δ r : X → Δ r:X rarr Deltar: X \rightarrow \Deltar:X→Δ to be a retract such that i is a retractible map with respect to r,we obtain a rixed polyt theoren for 1 1 ^(1){ }^{1}1 .
FHSOBJM 3 :If in the conditions in Theorem 1 , x : x → 118 1 , x : x → 118 1,x:x rarr1181, x: x \rightarrow 1181,x:x→118 a Fetract and I : A ⟶ I I : A ⟶ I I:A longrightarrow II: A \longrightarrow II:A⟶I ls retractible with respect to r r rrr ,then致和 f = 6 f = 6 f=6f=6f=6 .
Froof.From Theoren 1 it follows Fir rof ∉ g ∉ g !in g\notin g∉g and f f fff being retrac- tible with respect to r r rrr we have F i x f = F i x F i x f = F i x Fixf=FixF i x f=F i xFixf=Fix rof ∉ ∅ ∉ ∅ !in O/\notin \varnothing∉∅ .
comothary 3 (Theorem 5 in/6/).Let x ― x _ x_\underline{x}x― be a Hilbert space, ↑ ↑ uarr\uparrow↑ a nonvoid closed convex set, f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X a continuous 1-set-contrac- tive map.量e suppose that sither ( I ∼ p ∘ f ) ( A ) ( I ∼ p ∘ f ) ( A ) (I∼p@f)(A)(I \sim p \circ f)(\mathrm{A})(I∼p∘f)(A) is closed in X or (I-pof)(cl co p-f(A))is closed in X X XXX ,where P = P A P = P A P=P_(A)P=P_{A}P=PA is the netric projection.If f ( A ) f ( A ) f(A)f(A)f(A) is bounded and f f fff satisfies one of the following conditions :
(1)For each x x xxx in A A AAA ,there is a number λ λ lambda\lambdaλ(real or complex,de- pending on whether the vector space x x xxx is real or complex)such that | λ | < 1 | λ | < 1 |lambda| < 1|\lambda|<1|λ|<1 and λ x + ( 1 − λ ) f ( x ) ∈ Λ λ x + ( 1 − λ ) f ( x ) ∈ Λ lambda x+(1-lambda)f(x)in Lambda\lambda x+(1-\lambda) f(x) \in \Lambdaλx+(1−λ)f(x)∈Λ .
(2)For each x x xxx in 1 with x ≠ r ( x ) x ≠ r ( x ) x!=r(x)x \neq r(x)x≠r(x) ,there exists y y yyy in I A ( x ) == { x + c ( z − x ) : z ∈ A , c > 0 } I A ( x ) == { x + c ( z − x ) : z ∈ A , c > 0 } I_(A)(x)=={x+c(z-x):z in A,c > 0}I_{A}(x)= =\{x+c(z-x): z \in A, c>0\}IA(x)=={x+c(z−x):z∈A,c>0} such that.
H y − f ( x ) ‖ < ‖ x − f ( x ) ‖ H y − f ( x ) ‖ < ‖ x − f ( x ) ‖ Hy-f(x)|| < ||x-f(x)||H y-f(x)\|<\| x-f(x) \|Hy−f(x)‖<‖x−f(x)‖.
(3) f f fff is weakly inward(i.e. f ( x ) ∈ f ( x ) ∈ f(x)inf(x) \inf(x)∈ al I A ( x ) I A ( x ) I_(A)(x)I_{A}(x)IA(x) for each x x xxx in A).
(4)For each u in the boundary of 1 with u = p ⋅ f ( u ) u = p ⋅ f ( u ) u=p*f(u)u=p \cdot f(u)u=p⋅f(u) ,u is a fixed point of 1 .
(5)For oach x x xxx in the boundary of A , ‖ f ( x ) − y ‖ ≤ ‖ x − y ‖ A , ‖ f ( x ) − y ‖ ≤ ‖ x − y ‖ A,||f(x)-y|| <= ||x-y||A,\|f(x)-y\| \leq\|x-y\|A,‖f(x)−y‖≤‖x−y‖ for some y y yyy in A A AAA .
Then I I III has a fixed point in A A AAA .
Proof.Corollary 2 applies,so Pix pof & ∞ & ∞ &oo\& \infty&∞ :Each of the five conditions implies(4) / 2 / / 2 / //2/// 2 //2/ ,which is in fact exactly Fix fof = = ===
This means that f : A → X f : A → X f:A rarr Xf: A \rightarrow Xf:A→X is retractible with respect to p p ppp and applying Theoxam 3 one has Fix £ ≠ ∅ £ ≠ ∅ £!=O/£ \neq \varnothing£≠∅.
We mention that the condition of the retractibility . Fix pot == == === === Pix f f fff takes in Eilbert spaces the rollowing equivalent forms t t ttt
(i) For each in in the boundary of i i iii which is not a fixed point for f f fff, there exists y y yyy in A A AAA such that
Ro ( f ( u ) − u , u − y ) < o ( f ( u ) − u , u − y ) < o (f(u)-u,u-y) < o(f(u)-u, u-y)<o(f(u)−u,u−y)<o.
(ii) Ror each 4 in the boundary of 4 which is not a fixed point for f f fff, there exists y y yyy in A A AAA such that
‖ y − f ( u ) ‖ < ‖ u − f ( u ) ‖ ‖ y − f ( u ) ‖ < ‖ u − f ( u ) ‖ ||y-f(u)|| < ||u-f(u)||\|y-f(u)\|<\|u-f(u)\|‖y−f(u)‖<‖u−f(u)‖.
(iii) For aach u u uuu in the boundary of A A AAA which is not a fixed potnt for t t ttt,
lim t → 0 t 1 t a ( ( 1 − t ) u + t f ( u ) , A ˙ ) < ‖ f ( u ) − u ! lim t → 0 t   1 t a ( ( 1 − t ) u + t f ( u ) , A ˙ ) < ‖ f ( u ) − u ! lim_(t rarr0_(t))(1)/(t)a((1-t)u+tf(u),A^(˙)) < ||f(u)-u!\underset{t \rightarrow 0_{t}}{\lim } \frac{1}{t} a((1-t) u+t f(u), \dot{A})<\| f(u)-u!limt→0t1ta((1−t)u+tf(u),A˙)<‖f(u)−u!.
The equivalence follows easily from the next lemme, which relies on the fact that in a llibert spiace for a closed conver set 1 and x x xxx in x x xxx one has p ( x ) = a p ( x ) = a p(x)=ap(x)=ap(x)=a iff Re ( x − a , y − a ) ≤ 0 ( x − a , y − a ) ≤ 0 (x-a,y-a) <= 0(x-a, y-a) \leq 0(x−a,y−a)≤0 for each ∃ ∃ EE\exists∃ in A ( p = P A A p = P A A(p=P_(A):}A\left(p=P_{A}\right.A(p=PA being the metric projection).
Lisen 2. Let X X XXX be a Eilbert Brace, A ⊆ X A ⊆ X A sube XA \subseteq XA⊆X a nomvoid closed convex set, a in A , x A , x A,xA, xA,x in X X XXX. The following assertions are equivalent : i c p ( x ) = 2 i c p ( x ) = 2 i^(c)p(x)=2i^{c} p(x)=2icp(x)=2, i.e. ‖ x − a ‖ ⩽ ‖ x − y ‖ ‖ x − a ‖ ⩽ ‖ x − y ‖ ||x-a|| <= ||x-y||\|x-a\| \leqslant\|x-y\|‖x−a‖⩽‖x−y‖ for aach y y yyy in.
2 0 lim t → 3 1 1 t d ( ( 1 − t ) a + t x , A ) = 2 0 lim t → 3   1 1 t d ( ( 1 − t ) a + t x , A ) = 2^(0)lim_(t rarr3)(1)/((1)/(t))d((1-t)a+tx,A)=2^{0} \underset{t \rightarrow 3}{\lim } \frac{1}{\frac{1}{t}} d((1-t) a+t x, A)=20limt→311td((1−t)a+tx,A)=
= lim t → 0 , 1 τ d ( ( 1 − t ) a + t x , A ) = = lim t → 0 ,   1 τ d ( ( 1 − t ) a + t x , A ) = =lim_(t rarr0,)(1)/(tau)d((1-t)a+tx,A)==\lim _{t \rightarrow 0,} \frac{1}{\tau} d((1-t) a+t x, A)==limt→0,1τd((1−t)a+tx,A)=
= inf lat 0 1 t d ( ( 1 − t ) a + t x , d ) = ‖ x − a ‖ = inf lat 0   1 t d ( ( 1 − t ) a + t x , d ) = ‖ x − a ‖ =i n f_(lat0)(1)/(t)d((1-t)a+tx,d)=||x-a||=\inf _{\operatorname{lat} 0} \frac{1}{t} d((1-t) a+t x, d)=\|x-a\|=inflat01td((1−t)a+tx,d)=‖x−a‖.
3 2 min ini 1 t d ( ( 1 − t ) a + σ x , A ) ⩾ ‖ x − i ‖ : 3 2 min ini    1 t d ( ( 1 − t ) a + σ x , A ) ⩾ ‖ x − i ‖ : 3^(2)min_("ini ")(1)/(t)d((1-t)a+sigma x,A) >= ||x-i||:3^{2} \min _{\text {ini }} \frac{1}{t} d((1-t) a+\sigma x, A) \geqslant\|x-i\|:32minini 1td((1−t)a+σx,A)⩾‖x−i‖:
⇒ 2 ∘ ⇒ 2 ∘ =>2^(@)\Rightarrow 2^{\circ}⇒2∘. Tree first equalities in 2 ∘ 2 ∘ 2^(@)2^{\circ}2∘.ase true because
the map ψ : 3 + ∖ { 0 } → R + , ψ ( t ) = 1 t d ( a + t ( x − a ) ψ : 3 + ∖ { 0 } → R + , ψ ( t ) = 1 t d ( a + t ( x − a ) psi:3_(+)\\{0}rarrR_(+),psi(t)=(1)/(t)d(a+t(x-a)\psi: 3_{+} \backslash\{0\} \rightarrow R_{+}, \psi(t)=\frac{1}{t} d(a+t(x-a)ψ:3+∖{0}→R+,ψ(t)=1td(a+t(x−a), i) is increaaine and
lim i ≥ t > 0 Ψ ( t ) = lim t > 0 Ψ ( t ) . Now inf i ≥ t > 0 i 2 ( t ) inf i ≥ 0 t I t d 2 ( t ( x − a ) , A − a ) = = ln 1 ≥ t > 0 ⁡ d 2 ( x − a , 1 t ( A − a ) ) = inf t ≥ 1 d 2 ( x − a , t ( d − a ) ) = = ligf t × 4 inf y ∈ A − 2 ‖ x − a − t y ‖ 2 = = inf y ∈ A − 2 inr t ≥ 1 ( t 2 ‖ y ‖ 2 − 2 t Re ( x − a , y ) + ‖ x − a ‖ 2 ) . lim i ≥ t > 0   Ψ ( t ) = lim t > 0   Ψ ( t ) .  Now  inf i ≥ t > 0 i 2 ( t )   inf i ≥ 0 t   I t d 2 ( t ( x − a ) , A − a ) = = ln 1 ≥ t > 0 ⁡ d 2 x − a , 1 t ( A − a ) = inf t ≥ 1   d 2 ( x − a , t ( d − a ) ) = = ligf t × 4 inf y ∈ A − 2   ‖ x − a − t y ‖ 2 = = inf y ∈ A − 2   inr t ≥ 1 t 2 ‖ y ‖ 2 − 2 t Re ( x − a , y ) + ‖ x − a ‖ 2 . {:[lim_(i >= t > 0)Psi(t)=lim_(t > 0)Psi(t).],[" Now "i n f_({:[i >= t > 0],[i^(2)(t)]:})i n f_({:[i >= 0],[t]:})(I)/(t)d^(2)(t(x-a)","A-a)=],[=ln_(1 >= t > 0)d^(2)(x-a,(1)/(t)(A-a))],[=i n f_(t >= 1)d^(2)(x-a","t(d-a))=],[=ligf_(t xx4)i n f_(y in A-2)||x-a-ty||^(2)=],[=i n f_(y in A-2)inr_(t >= 1)(t^(2)||y||^(2)-2t Re(x-a,y)+||x-a||^(2)).]:}\begin{aligned} & \lim _{i \geq t>0} \Psi(t)=\lim _{t>0} \Psi(t) . \\ & \text { Now } \inf _{\substack{i \geq t>0 \\ i^{2}(t)}} \inf _{\substack{i \geq 0 \\ t}} \frac{I}{t} d^{2}(t(x-a), A-a)= \\ & =\ln _{1 \geq t>0} d^{2}\left(x-a, \frac{1}{t}(A-a)\right) \\ & =\inf _{t \geq 1} d^{2}(x-a, t(d-a))= \\ & =\operatorname{ligf}_{t \times 4} \inf _{y \in A-2}\|x-a-t y\|^{2}= \\ & =\inf _{y \in A-2} \operatorname{inr}_{t \geq 1}\left(t^{2}\|y\|^{2}-2 t \operatorname{Re}(x-a, y)+\|x-a\|^{2}\right) . \end{aligned}limi≥t>0Ψ(t)=limt>0Ψ(t). Now infi≥t>0i2(t)infi≥0tItd2(t(x−a),A−a)==ln1≥t>0⁡d2(x−a,1t(A−a))=inft≥1d2(x−a,t(d−a))==ligft×4infy∈A−2‖x−a−ty‖2==infy∈A−2inrt≥1(t2‖y‖2−2tRe(x−a,y)+‖x−a‖2).
But A θ ( x − a , y ) = R θ ( x − a , y + a − a ) ≤ 0 A θ ( x − a , y ) = R θ ( x − a , y + a − a ) ≤ 0 A_(theta)(x-a,y)=R_(theta)(x-a,y+a-a) <= 0A_{\theta}(x-a, y)=R_{\theta}(x-a, y+a-a) \leq 0Aθ(x−a,y)=Rθ(x−a,y+a−a)≤0, because y + a ∈ a y + a ∈ a y+a inay+a \in \mathcal{a}y+a∈a, y d ( x ) == a y d ( x ) == a yd(x)==ay d(x)= =\mathrm{a}yd(x)==a.
It follows that the map to be unimized is increasing on [ Re ( x − a , y ) , + ∞ ) [ Re ( x − a , y ) , + ∞ ) [Re(x-a,y),+oo)[\operatorname{Re}(x-a, y),+\infty)[Re(x−a,y),+∞), hence also on [ 1 , + ∞ ) [ 1 , + ∞ ) [1,+oo)[1,+\infty)[1,+∞). The influua will be attained on t = 1 t = 1 t=1t=1t=1 and
inf 1 ≥ t > 0 ψ 2 ( t ) = int y ∈ A − a ‖ x − a − y ‖ 2 = = inf y ∈ A ‖ x − y ‖ 2 = ‖ x − a ‖ 2 inf 1 ≥ t > 0   ψ 2 ( t ) = int y ∈ A − a ‖ x − a − y ‖ 2 = = inf y ∈ A   ‖ x − y ‖ 2 = ‖ x − a ‖ 2 {:[i n f_(1 >= t > 0)psi^(2)(t)=int_(y in A-a)||x-a-y||^(2)=],[=i n f_(y in A)||x-y||^(2)=||x-a||^(2)]:}\begin{aligned} \inf _{1 \geq t>0} \psi^{2}(t) & =\operatorname{int}_{y \in A-a}\|x-a-y\|^{2}= \\ & =\inf _{y \in A}\|x-y\|^{2}=\|x-a\|^{2} \end{aligned}inf1≥t>0ψ2(t)=inty∈A−a‖x−a−y‖2==infy∈A‖x−y‖2=‖x−a‖2
and the implication is proved.
2 ∘ ⟹ 3 ∘ 2 ∘ ⟹ 3 ∘ 2^(@)Longrightarrow3^(@)2^{\circ} \Longrightarrow 3^{\circ}2∘⟹3∘ in obvious,
3 0 ⇒ 1 0 3 0 ⇒ 1 0 3^(0)=>1^(0)3^{0} \Rightarrow 1^{0}30⇒10. Te have ‖ x − a ‖ ≤ inf t → 0 1 t ( ( 1 − t ) a + t x , 1 ) ≤ ‖ x − a ‖ ≤ inf t → 0   1 t ( ( 1 − t ) a + t x , 1 ) ≤ ||x-a|| <= i n f_(t rarr0)(1)/(t)((1-t)a+tx,1) <=\|x-a\| \leq \inf _{t \rightarrow 0} \frac{1}{t}((1-t) a+t x, 1) \leq‖x−a‖≤inft→01t((1−t)a+tx,1)≤
≤ ψ ( 1 ) = d ( x , 1 ) ≤ ‖ x − y ‖ ≤ ψ ( 1 ) = d ( x , 1 ) ≤ ‖ x − y ‖ <= psi(1)=d(x,1) <= ||x-y||\leq \psi(1)=d(x, 1) \leq\|x-y\|≤ψ(1)=d(x,1)≤‖x−y‖
for each J J JJJ in Λ Λ Lambda\LambdaΛ.
Remark. The equivalence in Inama 2 is also true if λ λ lambda\lambdaλ is a prenifibertian space and 1 a complete convex set.
The assertions (i) - (iii) are all equivalent to the condition (4) in Cogollary 3.
For (1) one uses the fact that pof(u) ∉ u ∉ u !in u\notin u∉u is equiralent to the axistance of y y yyy in A A AAA such that B o ( u − f ( u ) , j − u ) > 0 , u s i n g B o ( u − f ( u ) , j − u ) > 0 , u s i n g Bo(u-f(u),j-u) > 0,usingB o(u-f(u), j-u)>0, u s i n gBo(u−f(u),j−u)>0,using the characteriation of the metric projection memtloned before Lawia 2 was given.
For (ii) one applias fust the definition of p ( f ( a ) ) p ( f ( a ) ) p(f(a))p(f(a))p(f(a)) and obtains inde inequality in (ii).
For (iii) wa use the equivalence 1 ∘ ⟺ 3 ∘ 1 ∘ ⟺ 3 ∘ 1^(@)Longleftrightarrow3^(@)1^{\circ} \Longleftrightarrow 3^{\circ}1∘⟺3∘ which was proved in Leana 2.
So the ascertiona (i) - (iii) ure fust reformulations of the Iact that she map f : Λ → X f : Λ → X f:Lambda rarr Xf: \Lambda \rightarrow Xf:Λ→X is retractible on A A AAA with respect to tiau retraction p.
The equivalence of (i) - (iii) was in fact proved in /9/, where (i) is called the Leray-Schauder condition, (ii) the BrowderPetryshy condition and (iii) the Cramer-Ray condition. Hare Te emphazised the rale of the properties of the metric projection in this equivalence.
We flnish the paper giving a mathod of approximation of fixed Folnts for maps with pol nonexpansive in liilbert spaces by a procedure sinilar to that in the proof of Theorem 1 .
THSOEN 4. Let X X XXX be a Hilbert space, A a nonvoid cloged convex subset of x , 1 ; A → X x , 1 ; A → X x,1;A rarr Xx, 1 ; A \rightarrow Xx,1;A→X a nap retraction an A A AAA with resp. at to the petric projection such that F = F = F=F=F= pol : Λ → Δ : Λ → Δ :Lambda rarr Delta: \Lambda \rightarrow \Delta:Λ→Δ is nonempansive and P ( 1 ) P ( 1 ) P(1)P(1)P(1) bounded.
Consider F k : Λ → Λ , F k ( x ) = k F ( x ) + ( 1 − k ) x 0 , 0 < k < 1 F k : Λ → Λ , F k ( x ) = k F ( x ) + ( 1 − k ) x 0 , 0 < k < 1 F_(k):Lambda rarr Lambda,F_(k)(x)=kF(x)+(1-k)x_(0),0 < k < 1F_{k}: \Lambda \rightarrow \Lambda, F_{k}(x)=k F(x)+(1-k) x_{0}, 0<k<1Fk:Λ→Λ,Fk(x)=kF(x)+(1−k)x0,0<k<1, k → 1 , x 0 ∈ C k → 1 , x 0 ∈ C k rarr1,x_(0)in Ck \rightarrow 1, x_{0} \in Ck→1,x0∈C and x k x k x_(k)x_{k}xk, the fixed point of the contraction F k F k F_(k)F_{k}Fk.
Then x k → k → 1 J 0 x k → k → 1 J 0 x_(k)rarr"k rarr1"J_(0)x_{k} \xrightarrow{k \rightarrow 1} J_{0}xk→k→1J0, whore J 0 J 0 J_(0)J_{0}J0 is the fixed point of f f fff which closest to x 0 x 0 x_(0)x_{0}x0.

Proof.

The flxad point act Fix F F FFF is nonvoid; let J 0 J 0 J_(0)J_{0}J0 be the fixad point
of F F FFF mileh is closest to x 0 x 0 x_(0)x_{0}x0. For F F FFF one applies the approxiation rasult in / 8 / / 8 / //8/// 8 //8/; for k n → n , k n ∈ ( 0 , 1 ) , n ∈ M k n → n , k n ∈ ( 0 , 1 ) , n ∈ M k_(n)rarr"n",k_(n)in(0,1),n in Mk_{n} \xrightarrow{n}, k_{n} \in(0,1), n \in Mkn→n,kn∈(0,1),n∈M, one obtains firstly that { x k n } x k n {x_(k_(n))}\left\{x_{k_{n}}\right\}{xkn} ne N N NNN is a bounded scquence. Phan a subsequence of { x k n } n ∈ N x k n n ∈ N {x_(k_(n))}n in N\left\{x_{k_{n}}\right\} n \in N{xkn}n∈N will converge veakij to a paint x x xxx. Using the dealiclosedness of I-I one obtatns x = y 0 x = y 0 x=y_(0)x=y_{0}x=y0 and then the strong convorgenco or { x k n } n ∈ M x k n n ∈ M {x_(k_(n))}_(n in M)\left\{x_{k_{n}}\right\}_{n \in M}{xkn}n∈M to y 0 y 0 y_(0)y_{0}y0
But Pix P = P P = P P=PP=PP=P ix I I III and the theorer is proved.

REFZENCES

  1. M. C. Anisiu, Fixed points of retraotible nappings with respect to the netric projection, "Babes-Bolyal" Univ., Fac. of Nath. Phys., Preprint nr. ?, 1988, 67-96
  2. M.C.Antstu, V.Anisia, On some conditions for the existence of the fixad points in Hilbert spaces, "Babes-Bolyai" Univ., Fac. of With. Phys., Preprint nr. 6, 1989, 93-100
  3. R.F.Brown, Retraction methods in Nielsen fixed point theory, Pacific J. Math. 115 (1984), 277-298
  4. W. Gheney, A.II.Goldstein, Proximity maps for convex sets, Proc. Amer. Math. Soc. lo (1959), 448-450
  5. G.Darbo, Punti uniti in transformazioni a condominio noncompatto, Rend. Sen. Mat. Univ. Padova 24 (1955), 54-92
  6. 笙C.Lin, C.L. Yen, Applications of the proximity nap to fixed point thzoreas in Hilbert spaces, J. Approx. Theory 22 (1968), 141-148
  7. I.A.Bus, The fired point structures and the retraction mappings
    principla, "Baves-Bolyili" Univ., Fac. of Bath., Freprint ar. 3, 1986, 175-184
  8. S.P.Singh, B. Watson, On approximating fixed points, Proc. of Syap. in Pure Math., Vol. 45 (1986), Part 2, 393-395
    F. T. T. Filliaason, The Leray-Schauder condition is necessary for existence of fixed points, Vol. 886, Lecture Notes in Math., Springer-Verlag, Berin.
Institutul de Matenaticá C.P. 68 I400 Cluj-Hapoca ROMANIM  Institutul de Matenaticá   C.P.  68  I400 Cluj-Hapoca   ROMANIM  {:[" Institutul de Matenaticá "],[" C.P. "68],[" I400 Cluj-Hapoca "],[" ROMANIM "]:}\begin{aligned} & \text { Institutul de Matenaticá } \\ & \text { C.P. } 68 \\ & \text { I400 Cluj-Hapoca } \\ & \text { ROMANIM } \end{aligned}á Institutul de Matenaticá  C.P. 68 I400 Cluj-Hapoca  ROMANIM 
This paper is in final form and no version of it is or will be Edbaitted for publication elsewhers.

1989

Related Posts