[1] M.C. Anisiu, Fixed points of retractible mappings with respect to the metric projection, ”Babes-Bolyai” Univ., Fac. of Math. Phys., Preprint nr.7, 1988, 87-96.
[2] M.C. Anisiu, V. Anisiu, On some conditions for the existence of the fixed points in Hilbert spaces, ”Babes-Bolyai” Univ., Fac. of Math. Phys., Preprint nr.6, 1989, 93-100.
[3] R.F. Brown, Retraction methods in Nielses fixed point theory, Pacific J. Math. 115 (1984), 277-298.
[4] W. Cheney, A.H. Goldstein, Proximity maps for convex sets, Proc. Amer. Math. Soc. 10 (1959), 448-450.
[5] G. Darbo, Punti uniti in transformazioni a condominio noncompatto, Rend. Sem. Mat. Univ. Padova 24 (1955), 84-92.
[6] T.C. Lin, C.L.Yen, Applications of the proximity map to fixed point theorems in Hilbert spaces, J. Approx. Theory 52 (1968), 141-148.
[7] I.A. Rus, The fixed point structures and the retraction mappings principle, ”Babes-Bolyai” Univ., Fac. of Math. Preprint nr.3, 1986, 175-184.
[8] S.P. Singh, B. Yatson, On approximating fixed points, Proc. of Symp. in Pure Math., Vol. 45 (1986), Part 2, 393-395.
[9] T.E. Willianson, The Leray-Schauder condition is necessary for existence of fixed points, Vol. 886, Lecture Notes in Math., Springer-Verlag, Berlin
1989-Anisiu-FixedPointTheorems
"BASES-BOLYAT" UNTVERSITT
Faculty of Cathematics and Digisies
Resuarch Seminars
Seminar on Punctional Analysis and Numerical Uetiods
Preprint Nr. 1, 1989, pp. 1 - 10.
FIXED POTNT THEORENS FOR
BÉTHACTITHETE MAPPINGS
Mira-Cristlana Anisiu
The fixed point theorems in this paper axtand some results in //6/// 6 /; if the retract is chosen to be the metric projection one abtains same known theorems.
We state firstly some dofinitions to be used in the following.
Iret XX be a nonvoid set and l!in A <= Xl \notin A \leq X. AA map rtX rarr Lambdar t X \rightarrow \Lambda is a reEract of XX on AA if the restriction of rr to the sot AA is tha identity map id _(A):A rarr A.A{ }_{A}: A \rightarrow A . A map f:A rarr Xf: A \rightarrow X is retractible on AA with respect to the retract xx if Fix rof =Fixf=F i x f, where "Fix" donotes the sot of the fixed points of 2 map /3,?,1/.
It is obvious that always Fix rof sube\subseteq Fix ff, so in the definition. of the rotractible map one can darand only Fix f sube Fixf \subseteq F i x rof. Brown in /3/ has given the following necossary and sufficient condition for the map f:A rarr Xf: A \rightarrow X to ba ratractible on AA with raspect te, the retract r : x^(˙)in r(f(A)\\A)\dot{x} \in r(f(A) \backslash A) impliss f(x)=xf(x)=x or f(x)!inr^(-1)(x)f(x) \notin r^{-1}(x).
Lat BB be a bounded nonampty sat in tha patric spaca XX. The gassure of noncompactness in tha zanse of Kuratowsty, denated a(B)a(B), is the infimum of the numbers alpha\alpha such that the set BB can be covered
by 4 finite namber of subsets of XX of diameter leas than or equal to alpha\alpha.
Let AA be a monvoid subset of the metric space bar(X)\bar{X} and I:A rarr XI: A \rightarrow X a aap. If there exists k,c <= k <= 1k, c \leqslant k \leqslant 1 such that for each nonempty subset BB of A, B baing bounded, wo have a(f(B)) <= ka(B)a(f(B)) \leqslant k a(B),
then ff is called xx-set-contractive.
Bach nonexpansive map f:Lambda rarr X(f: \Lambda \rightarrow X( i.e. d(f(x),f(y)) <= d(x,y)d(f(x), f(y)) \leqslant d(x, y) for each x,yx, y in A) is obviously l-eiet-contractive.
In. the following we give a generalization of Theorem I in /6/, using in the proof the fixed point theoren of Darbot
THEORS: 1 /5/. Let XX be a Banach space, A sube XA \subseteq X a closed convex nonvoid set, f:A longrightarrow Af: A \longrightarrow A continuous kk-set-contractive with 0 < k < j0<k<j. such that Z(A)\mathbb{Z}(\mathbb{A}) is a bounded set. Then Fix f!=O/f \neq \varnothing.
In the initial form of Darbo'a theorem A is bounded, but it :'\because suffices to roquiro f(A)f(A) bounded, taking A_(1)=clcof(A)sube AA_{1}=c l c o f(A) \subseteq A and f:A_(1)rarrA_(1)f: A_{1} \rightarrow A_{1}.
Me nead also the following
Insuld 1. Let XX be a normed space, C sube XC \subseteq X and f:C longrightarrow Xf: C \longrightarrow X, such that (I-f)(C)(I-f)(C) is a closed sot. If there oxiats a sequonce of ㄱapsf n,C rarr X,n >= 1n, C \rightarrow X, n \geqslant 1, each of them having e fixed point x_(n)(f_(n)(x_(n))=x_(n)),f_(n)x_{n} \left(f_{n}\left(x_{n}\right)=x_{n}\right), f_{n} converging uniformly to f_(1)f_{1} then f_("has also a fixed ")f_{\text {has also a fixed }} point.
Proof. Denote s,g_(n):C rarrI,g=I-f,g_(n)=I-f_(n),n >= 1\mathrm{s}, \mathrm{g}_{\mathrm{n}}: C \rightarrow \mathrm{I}, \mathrm{g}=I-f, \mathrm{~g}_{\mathrm{n}}=I-f_{\mathrm{n}}, n \geq 1. Fach I_(n)I_{n} having a fixed point, it follows that each g_(n)g_{n} has a zero, heace o ing_(n)(d)o \in g_{n}(d). Because f_(n)rarr"n"ff_{n} \xrightarrow{n} f uniforaly; g_(n)rarr"n"gg_{n} \xrightarrow{n} g uniformly.
Int epsi > 0\varepsilon>0 be arbitrarily chosen; Irom the uniform convergenció of g_(n)g_{n} to gg one obtains g_(6) >= 1g_{6} \geqslant 1 such that ||g_(x)(x)-g(x)|| < epsi\left\|g_{x}(x)-g(x)\right\|<\varepsilon for each n >= n_(epsi)n \geqslant n_{\varepsilon} and xx in CC.
It follows that for each n >= n_(E)n \geqslant n_{E} we have E_(n)(C)sube E(C)+B(0,E)E_{n}(C) \subseteq E(C)+B(0, E).
Therafore 0in E(C)+B(0,epsi)0 \in E(C)+B(0, \varepsilon) for each epsi > 0\varepsilon>0 and 0in0 \in cl g(C)g(C). =g(C)=g(C). This means'that there exists x in Cx \in C such that f(x)=x^(˙)f(x)=\dot{x}.
Now we can prove the following
THEOREM 2. Let XX be a Banach spēce, A sube XA \subseteq X a nonvoid closéd convex set; f:A rarr Xf: A \rightarrow X and r:X rarr Ar: X \rightarrow A such that F=F= rof :A rarr A: A \rightarrow A is a continuous 1-set-contractive map having P(A)P(A) bounded and (I-f)(A)(I-f)(A) a closed set. Then Fix rof !in O/\notin \varnothing.
Proof. Let t in(0,1),x_(0)in At \in(0,1), x_{0} \in A and F_(t)=tF+(1-t)x_(0)F_{t}=t F+(1-t) x_{0}. We show that F_(t)F_{t} is tt-set contractive.
Let B sube AB \subseteq A a bounded subset ; then a(F_(t)(B))=a(tP(B)+(I-t)x_(0)) <= a(tP(B))=ta(P(B)) <= ta(B)a\left(F_{t}(B)\right)=a\left(t P(B)+(I-t) x_{0}\right) \leqslant a(t P(B))=t a(P(B)) \leqslant t a(B).
Applying Darbo's theorem, each F_(t)F_{t} has a fixed point x_(t)x_{t}. Considering t_(n)rarr1,t_(n) < 1t_{n} \rightarrow 1, t_{n}<1 we obtain for each xx in AA ||F_(t_(n))(x)-F(x)||=(1-t_(n))||F(x)-x_(0)|| <=\left\|F_{t_{n}}(x)-F(x)\right\|=\left(1-t_{n}\right)\left\|F(x)-x_{0}\right\| \leqslant <= (1-t_(n))d(x_(0)^('),F(A))rarr"t_(n)rarr1"0,\leqslant\left(1-t_{n}\right) d\left(x_{0}^{\prime}, F(A)\right) \xrightarrow{t_{n} \rightarrow 1} 0,.
bence F_(t_(n))longrightarrow F\mathrm{F}_{\mathrm{t}_{\mathrm{n}}} \longrightarrow F uniformly on A .
Now Lema 1 applies and Fix F!in O/F \notin \varnothing.
In the above theorem, instead of (I-F)(Lambda)(I-F)(\Lambda) to be closod, one could require ( I-FI-F ) (cl co F(A)F(A) ) to be closed to XX, considering the restriction of FF on el co F(A)F(A), whose range is also in cl co vec(r)(A)\vec{r}(A).
In the terms of FF, Theorem 2 is exactely Lemma 1 in //6/// 6 /, given there without proof.
4 natural example of a map x:X rarr Ax: X \rightarrow A is the meteric projection, which is well-defined if for mample xx is aniformly convex.In thls case we obtain obviously
COROLTARY 1.Let XX be a prifornaly convex Bagach Boach i sube Xi \subseteq X ㅡ nonvoid closed convex fat,f:A rarr Xf: A \rightarrow X ang P=F,tx rarr AP=F, t x \rightarrow A the metric projection.If P=p@f:A rarr AP=p \circ f: A \rightarrow A as a continuigs 1-getcog- tructive men with F(Lambda)F(\Lambda) bounded and(I.F )( AA )cloged get,then Rix pof !=0\neq 0 .
The conclusion means axactely that there oxists xx in a ach that par (x)=x,(1)/(4),0.1-f(x)=d(f(x),1)(x)=x, \frac{1}{4}, 0.1-f(x)=d(f(x), 1) this raspht appears in the well-icnomn theorem of bar(X)y\bar{X} y Fan(1969)gtyan for a namveld com- pact convex subset KK of a normed space XX and continuous map II : :KlongrightarrowK: \mathrm{K} \longrightarrow \mathrm{K}. a nonvoid slosed convex set,f:A rarr Xf: A \rightarrow X ig continuous 1-1- setchontrac- tive map.We suppose that althgr (I-pof)(A)(I-p o f)(A) is closed gr( I-I- -pof)(cl co pef(A))is closed in xx, whers p=P_(A):x rarr Ap=P_{A}: x \rightarrow A is the metric profection.If f(A)f(A) is bounded,then there exists u in such that ||u-f(u)||=d(f(u),Lambda)\|u-f(u)\|=d(f(u), \Lambda).
Proof.Because f,t rarrX^(˙)f, t \rightarrow \dot{X} is continneus 1-set-contractive and i p:X rarr Ap: X \rightarrow A is nonexpansive //4/// 4 / ,it follows that F=parF=p a r is a conti- nuous 1-sht-contractive map.The fact that f(A)f(A) is bourded implios F(A)F(A) boundad and Cerellary 1 applies.
It is obvieus that in Caroliary 2 ,ingtend of 1(1)1(1) to be bounded it is enough the require pof(A)to be boandad.
In the papar/4/there mew given many results which fallow from Corsllary 2,mong mich theorems of Isn,Singh and Hatison.
If in Theorein 1 we can choose r:X rarr Deltar: X \rightarrow \Delta to be a retract such that i is a retractible map with respect to r,we obtain a rixed polyt theoren for ^(1){ }^{1} .
FHSOBJM 3 :If in the conditions in Theorem 1,x:x rarr1181, x: x \rightarrow 118 a Fetract and I:A longrightarrow II: A \longrightarrow I ls retractible with respect to rr ,then致和 f=6f=6 .
Froof.From Theoren 1 it follows Fir rof !in g\notin g and ff being retrac- tible with respect to rr we have Fixf=FixF i x f=F i x rof !in O/\notin \varnothing .
comothary 3 (Theorem 5 in/6/).Let x_\underline{x} be a Hilbert space,uarr\uparrow a nonvoid closed convex set,f:A rarr Xf: A \rightarrow X a continuous 1-set-contrac- tive map.量e suppose that sither (I∼p@f)(A)(I \sim p \circ f)(\mathrm{A}) is closed in X or (I-pof)(cl co p-f(A))is closed in XX ,where P=P_(A)P=P_{A} is the netric projection.If f(A)f(A) is bounded and ff satisfies one of the following conditions :
(1)For each xx in AA ,there is a number lambda\lambda(real or complex,de- pending on whether the vector space xx is real or complex)such that |lambda| < 1|\lambda|<1 and lambda x+(1-lambda)f(x)in Lambda\lambda x+(1-\lambda) f(x) \in \Lambda .
(2)For each xx in 1 with x!=r(x)x \neq r(x) ,there exists yy in I_(A)(x)=={x+c(z-x):z in A,c > 0}I_{A}(x)= =\{x+c(z-x): z \in A, c>0\} such that. Hy-f(x)|| < ||x-f(x)||H y-f(x)\|<\| x-f(x) \|.
(3)ff is weakly inward(i.e.f(x)inf(x) \in al I_(A)(x)I_{A}(x) for each xx in A).
(4)For each u in the boundary of 1 with u=p*f(u)u=p \cdot f(u) ,u is a fixed point of 1 .
(5)For oach xx in the boundary of A,||f(x)-y|| <= ||x-y||A,\|f(x)-y\| \leq\|x-y\| for some yy in AA .
Then II has a fixed point in AA .
Proof.Corollary 2 applies,so Pix pof &oo\& \infty :Each of the five conditions implies(4)//2/// 2 / ,which is in fact exactly Fix fof ==
This means that f:A rarr Xf: A \rightarrow X is retractible with respect to pp and applying Theoxam 3 one has Fix £!=O/£ \neq \varnothing.
We mention that the condition of the retractibility . Fix pot === = Pix ff takes in Eilbert spaces the rollowing equivalent forms tt
(i) For each in in the boundary of ii which is not a fixed point for ff, there exists yy in AA such that
Ro (f(u)-u,u-y) < o(f(u)-u, u-y)<o.
(ii) Ror each 4 in the boundary of 4 which is not a fixed point for ff, there exists yy in AA such that ||y-f(u)|| < ||u-f(u)||\|y-f(u)\|<\|u-f(u)\|.
(iii) For aach uu in the boundary of AA which is not a fixed potnt for tt, lim_(t rarr0_(t))(1)/(t)a((1-t)u+tf(u),A^(˙)) < ||f(u)-u!\underset{t \rightarrow 0_{t}}{\lim } \frac{1}{t} a((1-t) u+t f(u), \dot{A})<\| f(u)-u!.
The equivalence follows easily from the next lemme, which relies on the fact that in a llibert spiace for a closed conver set 1 and xx in xx one has p(x)=ap(x)=a iff Re (x-a,y-a) <= 0(x-a, y-a) \leq 0 for each EE\exists in A(p=P_(A):}A\left(p=P_{A}\right. being the metric projection).
Lisen 2. Let XX be a Eilbert Brace, A sube XA \subseteq X a nomvoid closed convex set, a in A,xA, x in XX. The following assertions are equivalent : i^(c)p(x)=2i^{c} p(x)=2, i.e. ||x-a|| <= ||x-y||\|x-a\| \leqslant\|x-y\| for aach yy in. 2^(0)lim_(t rarr3)(1)/((1)/(t))d((1-t)a+tx,A)=2^{0} \underset{t \rightarrow 3}{\lim } \frac{1}{\frac{1}{t}} d((1-t) a+t x, A)= =lim_(t rarr0,)(1)/(tau)d((1-t)a+tx,A)==\lim _{t \rightarrow 0,} \frac{1}{\tau} d((1-t) a+t x, A)= =i n f_(lat0)(1)/(t)d((1-t)a+tx,d)=||x-a||=\inf _{\operatorname{lat} 0} \frac{1}{t} d((1-t) a+t x, d)=\|x-a\|. 3^(2)min_("ini ")(1)/(t)d((1-t)a+sigma x,A) >= ||x-i||:3^{2} \min _{\text {ini }} \frac{1}{t} d((1-t) a+\sigma x, A) \geqslant\|x-i\|: =>2^(@)\Rightarrow 2^{\circ}. Tree first equalities in 2^(@)2^{\circ}.ase true because
the map psi:3_(+)\\{0}rarrR_(+),psi(t)=(1)/(t)d(a+t(x-a)\psi: 3_{+} \backslash\{0\} \rightarrow R_{+}, \psi(t)=\frac{1}{t} d(a+t(x-a), i) is increaaine and
{:[lim_(i >= t > 0)Psi(t)=lim_(t > 0)Psi(t).],[" Now "i n f_({:[i >= t > 0],[i^(2)(t)]:})i n f_({:[i >= 0],[t]:})(I)/(t)d^(2)(t(x-a)","A-a)=],[=ln_(1 >= t > 0)d^(2)(x-a,(1)/(t)(A-a))],[=i n f_(t >= 1)d^(2)(x-a","t(d-a))=],[=ligf_(t xx4)i n f_(y in A-2)||x-a-ty||^(2)=],[=i n f_(y in A-2)inr_(t >= 1)(t^(2)||y||^(2)-2t Re(x-a,y)+||x-a||^(2)).]:}\begin{aligned}
& \lim _{i \geq t>0} \Psi(t)=\lim _{t>0} \Psi(t) . \\
& \text { Now } \inf _{\substack{i \geq t>0 \\
i^{2}(t)}} \inf _{\substack{i \geq 0 \\
t}} \frac{I}{t} d^{2}(t(x-a), A-a)= \\
& =\ln _{1 \geq t>0} d^{2}\left(x-a, \frac{1}{t}(A-a)\right) \\
& =\inf _{t \geq 1} d^{2}(x-a, t(d-a))= \\
& =\operatorname{ligf}_{t \times 4} \inf _{y \in A-2}\|x-a-t y\|^{2}= \\
& =\inf _{y \in A-2} \operatorname{inr}_{t \geq 1}\left(t^{2}\|y\|^{2}-2 t \operatorname{Re}(x-a, y)+\|x-a\|^{2}\right) .
\end{aligned}
But A_(theta)(x-a,y)=R_(theta)(x-a,y+a-a) <= 0A_{\theta}(x-a, y)=R_{\theta}(x-a, y+a-a) \leq 0, because y+a inay+a \in \mathcal{a}, yd(x)==ay d(x)= =\mathrm{a}.
It follows that the map to be unimized is increasing on [Re(x-a,y),+oo)[\operatorname{Re}(x-a, y),+\infty), hence also on [1,+oo)[1,+\infty). The influua will be attained on t=1t=1 and
{:[i n f_(1 >= t > 0)psi^(2)(t)=int_(y in A-a)||x-a-y||^(2)=],[=i n f_(y in A)||x-y||^(2)=||x-a||^(2)]:}\begin{aligned}
\inf _{1 \geq t>0} \psi^{2}(t) & =\operatorname{int}_{y \in A-a}\|x-a-y\|^{2}= \\
& =\inf _{y \in A}\|x-y\|^{2}=\|x-a\|^{2}
\end{aligned}
and the implication is proved. 2^(@)Longrightarrow3^(@)2^{\circ} \Longrightarrow 3^{\circ} in obvious, 3^(0)=>1^(0)3^{0} \Rightarrow 1^{0}. Te have ||x-a|| <= i n f_(t rarr0)(1)/(t)((1-t)a+tx,1) <=\|x-a\| \leq \inf _{t \rightarrow 0} \frac{1}{t}((1-t) a+t x, 1) \leq
for each JJ in Lambda\Lambda.
Remark. The equivalence in Inama 2 is also true if lambda\lambda is a prenifibertian space and 1 a complete convex set.
The assertions (i) - (iii) are all equivalent to the condition (4) in Cogollary 3.
For (1) one uses the fact that pof(u) !in u\notin u is equiralent to the axistance of yy in AA such that Bo(u-f(u),j-u) > 0,usingB o(u-f(u), j-u)>0, u s i n g the characteriation of the metric projection memtloned before Lawia 2 was given.
For (ii) one applias fust the definition of p(f(a))p(f(a)) and obtains inde inequality in (ii).
For (iii) wa use the equivalence 1^(@)Longleftrightarrow3^(@)1^{\circ} \Longleftrightarrow 3^{\circ} which was proved in Leana 2.
So the ascertiona (i) - (iii) ure fust reformulations of the Iact that she map f:Lambda rarr Xf: \Lambda \rightarrow X is retractible on AA with respect to tiau retraction p.
The equivalence of (i) - (iii) was in fact proved in /9/, where (i) is called the Leray-Schauder condition, (ii) the BrowderPetryshy condition and (iii) the Cramer-Ray condition. Hare Te emphazised the rale of the properties of the metric projection in this equivalence.
We flnish the paper giving a mathod of approximation of fixed Folnts for maps with pol nonexpansive in liilbert spaces by a procedure sinilar to that in the proof of Theorem 1 .
THSOEN 4. Let XX be a Hilbert space, A a nonvoid cloged convex subset of x,1;A rarr Xx, 1 ; A \rightarrow X a nap retraction an AA with resp. at to the petric projection such that F=F= pol :Lambda rarr Delta: \Lambda \rightarrow \Delta is nonempansive and P(1)P(1) bounded.
Consider F_(k):Lambda rarr Lambda,F_(k)(x)=kF(x)+(1-k)x_(0),0 < k < 1F_{k}: \Lambda \rightarrow \Lambda, F_{k}(x)=k F(x)+(1-k) x_{0}, 0<k<1, k rarr1,x_(0)in Ck \rightarrow 1, x_{0} \in C and x_(k)x_{k}, the fixed point of the contraction F_(k)F_{k}.
Then x_(k)rarr"k rarr1"J_(0)x_{k} \xrightarrow{k \rightarrow 1} J_{0}, whore J_(0)J_{0} is the fixed point of ff which closest to x_(0)x_{0}.
Proof.
The flxad point act Fix FF is nonvoid; let J_(0)J_{0} be the fixad point
of FF mileh is closest to x_(0)x_{0}. For FF one applies the approxiation rasult in //8/// 8 /; for k_(n)rarr"n",k_(n)in(0,1),n in Mk_{n} \xrightarrow{n}, k_{n} \in(0,1), n \in M, one obtains firstly that {x_(k_(n))}\left\{x_{k_{n}}\right\} ne NN is a bounded scquence. Phan a subsequence of {x_(k_(n))}n in N\left\{x_{k_{n}}\right\} n \in N will converge veakij to a paint xx. Using the dealiclosedness of I-I one obtatns x=y_(0)x=y_{0} and then the strong convorgenco or {x_(k_(n))}_(n in M)\left\{x_{k_{n}}\right\}_{n \in M} to y_(0)y_{0}
But Pix P=PP=P ix II and the theorer is proved.
REFZENCES
M. C. Anisiu, Fixed points of retraotible nappings with respect to the netric projection, "Babes-Bolyal" Univ., Fac. of Nath. Phys., Preprint nr. ?, 1988, 67-96
M.C.Antstu, V.Anisia, On some conditions for the existence of the fixad points in Hilbert spaces, "Babes-Bolyai" Univ., Fac. of With. Phys., Preprint nr. 6, 1989, 93-100
R.F.Brown, Retraction methods in Nielsen fixed point theory, Pacific J. Math. 115 (1984), 277-298
W. Gheney, A.II.Goldstein, Proximity maps for convex sets, Proc. Amer. Math. Soc. lo (1959), 448-450
G.Darbo, Punti uniti in transformazioni a condominio noncompatto, Rend. Sen. Mat. Univ. Padova 24 (1955), 54-92
笙C.Lin, C.L. Yen, Applications of the proximity nap to fixed point thzoreas in Hilbert spaces, J. Approx. Theory 22 (1968), 141-148
I.A.Bus, The fired point structures and the retraction mappings
principla, "Baves-Bolyili" Univ., Fac. of Bath., Freprint ar. 3, 1986, 175-184
S.P.Singh, B. Watson, On approximating fixed points, Proc. of Syap. in Pure Math., Vol. 45 (1986), Part 2, 393-395
F. T. T. Filliaason, The Leray-Schauder condition is necessary for existence of fixed points, Vol. 886, Lecture Notes in Math., Springer-Verlag, Berin.
{:[" Institutul de Matenaticá "],[" C.P. "68],[" I400 Cluj-Hapoca "],[" ROMANIM "]:}\begin{aligned}
& \text { Institutul de Matenaticá } \\
& \text { C.P. } 68 \\
& \text { I400 Cluj-Hapoca } \\
& \text { ROMANIM }
\end{aligned}
This paper is in final form and no version of it is or will be Edbaitted for publication elsewhers.

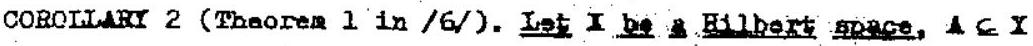 a nonvoid slosed convex set,